Areas - 초정밀회전기기 연구실
폐색성 혈관질환 치료를 위한 자기구동형 마이크로로봇 시스템의 개발
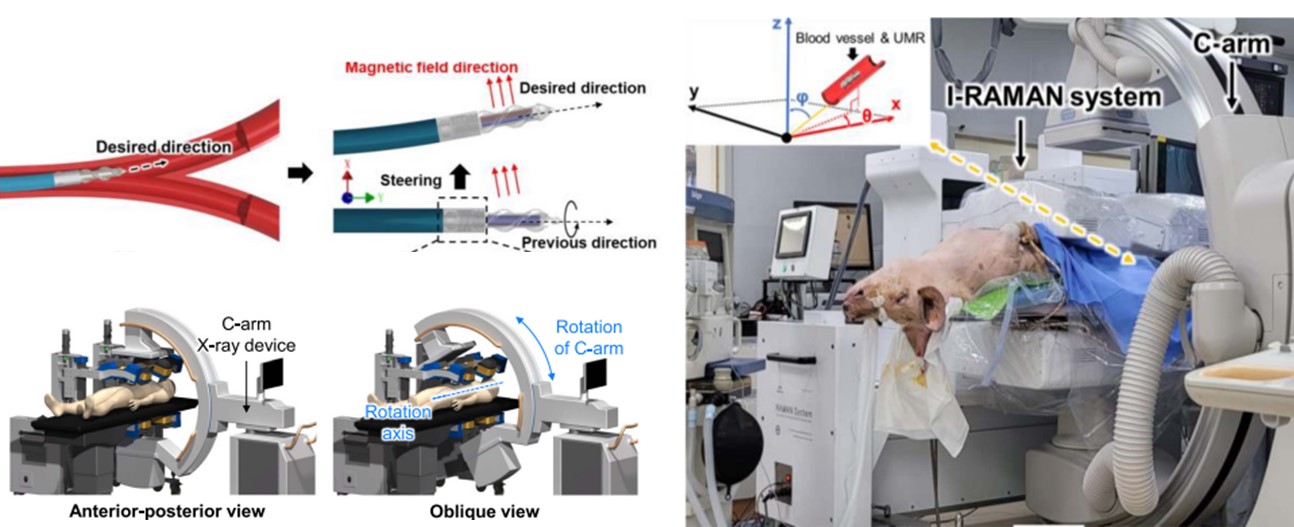
마이크로로봇을 사용하여 혈관 내의 치료 부위에 자기구동으로 도달하여 혈관 개통, 스텐트 설치, 약물 전달하는 원격시술용 자기로봇시스템 연구를 수행하고 있습니다. 폐색된 혈관은 뇌졸중, 심근경색, 말초 동맥 질환 등 폐쇄성 혈관 질환(OVD)의 주요 원인으로, 기존의 시술 방법은 수술 도구를 수동으로 조작해야 하고, 의료진이 높은 방사선에 노출되는 문제점이 있었습니다. 본 연구에서는 외부 자기장으로 구동되는 무선 로봇을 개발하여 이러한 난점을 해결하였고, X-ray 이미지를 기반으로 생성된 3D 혈관지도를 사용하여 혈관 치료를 수행하였습니다. 나아가, PREM은 돼지의 대퇴 동맥(Superficial femoral artery)에서 동물실험을 수행하여 기술의 실현 가능성을 검증하였습니다. PREM은 자기구동형 마이크로 로봇 시스템의 상용화를 목표로 하여 InterMag 라는 바이오 벤처 회사를 설립하였고, 향후 임상 시험을 계획하고 있습니다. 관련연구는 IEEE Robotics and Automation Letters등에 발표하고 있으며, IEEE Spectrum에 본 연구실의 연구내용이 특집 보도 되었습니다.
Company: https://intermag.co.kr
Published paper: https://ieeexplore.ieee.org/abstract/document/10041766
Article: https://spectrum.ieee.org/mini-robot-surgeon
전소화기관 자동 검진을 위한 자기캡슐내시경의 정밀 제어 연구
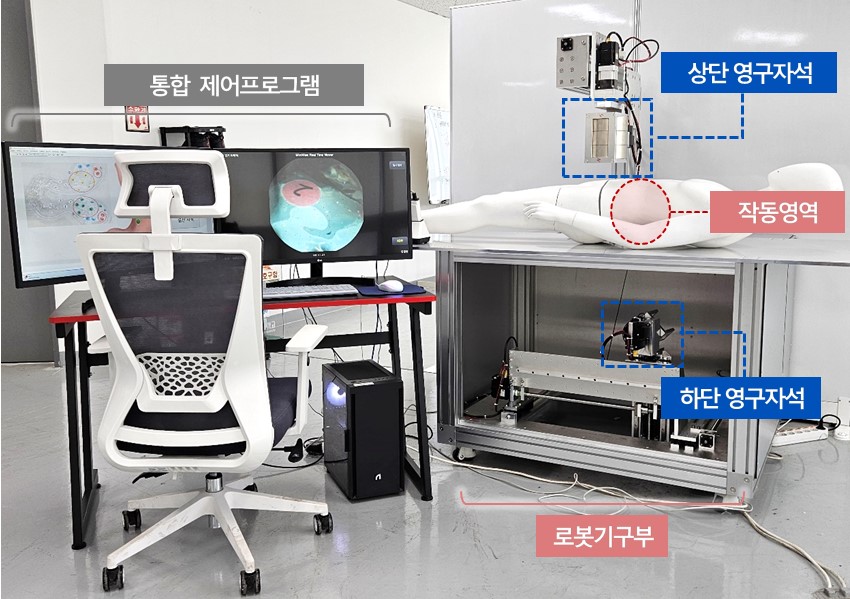
유선내시경은 오랜 기간 동안 위장검진을 위한 좋은 도구로 사용되었으나, 위장관 내에 상처가 존재하거나, 수면검진이 불가한 환자들이 내시경 검진을 받지 못하는 어려움이 존재하였습니다. 이런 문제를 해결하기 위해 알약과 같은 자기 캡슐내시경이 개발되었습니다. 본 연구실에서는 캡슐내시경의 위치와 자세를 정밀하게 제어하기 위한 자기구동시스템(C-RAMAN system)을 개발하여 전소화기관의 검진이 가능하도록 연구하고 있습니다. C-RAMAN system은 자기장을 생성 제어하는 상하단 영구자석부, 영구자석부를 정밀하게 이동시키는 로봇기구부와 통합제어프로그램으로 구성되고, 상·하단 영구자석의 각각 5자유도 운동을 통해 체내의 캡슐내시경은 소화기관 전체에 대한 정밀 검진이 가능하며, 환자의 자세 변화 없이 위장 전체를 정밀 검진할 수 있으며, 이를 통해 Full-automatic 검진이 가능합니다. 관련연구는 IEEE Transactions on Industrial Electronics 등에 발표하고 있습니다.
Published paper: https://ieeexplore.ieee.org/abstract/document/10049799
로터-씰 시스템의 동적 모델 개발을 위한 층류, 난류 및 슬립 조건의 영향 분석
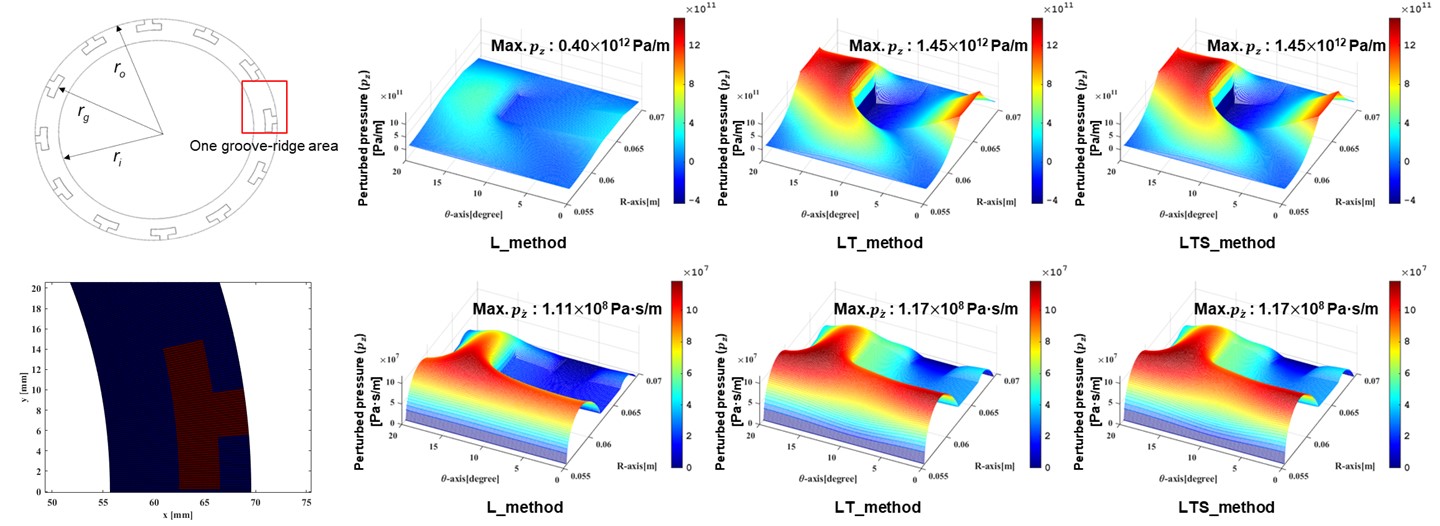
건식 가스 씰의 동적 계수는 로터-씰 시스템의 동적 특성에 영향을 미칩니다. 본 연구에서는 층류, 난류 및 슬립 효과에 따라 건식 가스 씰의 동적 계수를 계산하기 위해 수학적 섭동 방법을 제안하였습니다. 제안된 방법에서는 층류, 난류 및 슬립 조건의 영향을 포함하는 수정된 레이놀즈 방정식의 섭동 방정식을 도출하였습니다. 수정된 레이놀즈 방정식의 압력은 유한 요소법과 뉴턴-랩슨 방법을 결합한 알고리즘을 통해 결정되었으며, 계산된 압력을 섭동 방정식에 대입하여 각 자유도에 대한 섭동 압력을 계산했습니다. 본 연구는 건식 가스 씰의 동적 계수를 예측함으로써 로터-씰 시스템의 동적 모델을 개발할 수 있게 하며, 다양한 작동 환경에서 견고하고 안정적인 건식 가스 씰 개발에 기여하였습니다. 관련연구는 Tribology International, Lubricants등에 발표하고 있습니다.
Published paper: https://www.mdpi.com/2075-4442/11/3/98
Development of a Magnetically Actuated Microrobot System for the Treatment of Occlusive Vascular Diseases
We are developing a magnetically actuated microrobot system for the treatment of occlusive vascular diseases. Using external magnetic fields, wireless microrobots can be guided to target sites within blood vessels for vascular recanalization, stent deployment, and drug delivery. To overcome the limitations of conventional manual interventions and reduce radiation exposure to medical staff, we integrate magnetic actuation with three-dimensional vascular maps reconstructed from X-ray images. The feasibility of this technology has been demonstrated through in vivo animal experiments in the superficial femoral artery of pigs. To accelerate clinical translation and commercialization, PREM established the biomedical venture company InterMag, and related research outcomes have been published in IEEE Robotics and Automation Letters and featured in IEEE Spectrum.
Company: https://intermag.co.kr
Published paper: https://ieeexplore.ieee.org/abstract/document/10041766
Article: https://spectrum.ieee.org/mini-robot-surgeon
Precise Control of a Magnetic Capsule Endoscope for Full-Automatic Gastrointestinal Examination
Conventional wired endoscopy has long been used as an effective tool for gastrointestinal examination. However, patients with lesions in the gastrointestinal tract or those who cannot undergo sedated procedures often face difficulties in receiving endoscopic examinations. To address these limitations, pill-sized magnetic capsule endoscopes have been developed. Our laboratory is conducting research on a magnetic actuation system, the C-RAMAN system, for the precise control of the position and orientation of capsule endoscopes, with the goal of enabling examination of the entire gastrointestinal tract. The C-RAMAN system consists of upper and lower permanent magnet units for generating and controlling magnetic fields, a robotic mechanism for precise magnet motion, and an integrated control program. Through the five-degree-of-freedom motion of both the upper and lower permanent magnet units, the capsule endoscope can be precisely guided throughout the gastrointestinal tract, enabling comprehensive examination of the stomach without requiring changes in patient posture. This approach provides a foundation for fully automated gastrointestinal examination. Related research outcomes have been published in IEEE Transactions on Industrial Electronics and other journals.
Published paper: https://ieeexplore.ieee.org/abstract/document/10049799
Influence Analysis of Laminar, Turbulent, and Slip Conditions for the Development of a Dynamic Model of a Rotor–Seal System
The dynamic coefficients of dry gas seals significantly affect the dynamic characteristics of rotor–seal systems. Our laboratory has proposed a mathematical perturbation method to calculate the dynamic coefficients of dry gas seals under laminar, turbulent, and slip flow conditions. In this approach, perturbation equations were derived from a modified Reynolds equation that incorporates the effects of laminar flow, turbulent flow, and slip conditions. The pressure distribution of the modified Reynolds equation was determined using an algorithm that combines the finite element method with the Newton–Raphson method, and the calculated pressure was substituted into the perturbation equations to obtain perturbation pressures for each degree of freedom. By enabling the prediction of the dynamic coefficients of dry gas seals, this research provides a basis for the development of dynamic models of rotor–seal systems and contributes to the design of robust and reliable dry gas seals under a wide range of operating conditions. Related research outcomes have been published in Tribology International, Lubricants, and other journals.
Published paper: https://www.mdpi.com/2075-4442/11/3/98